 01
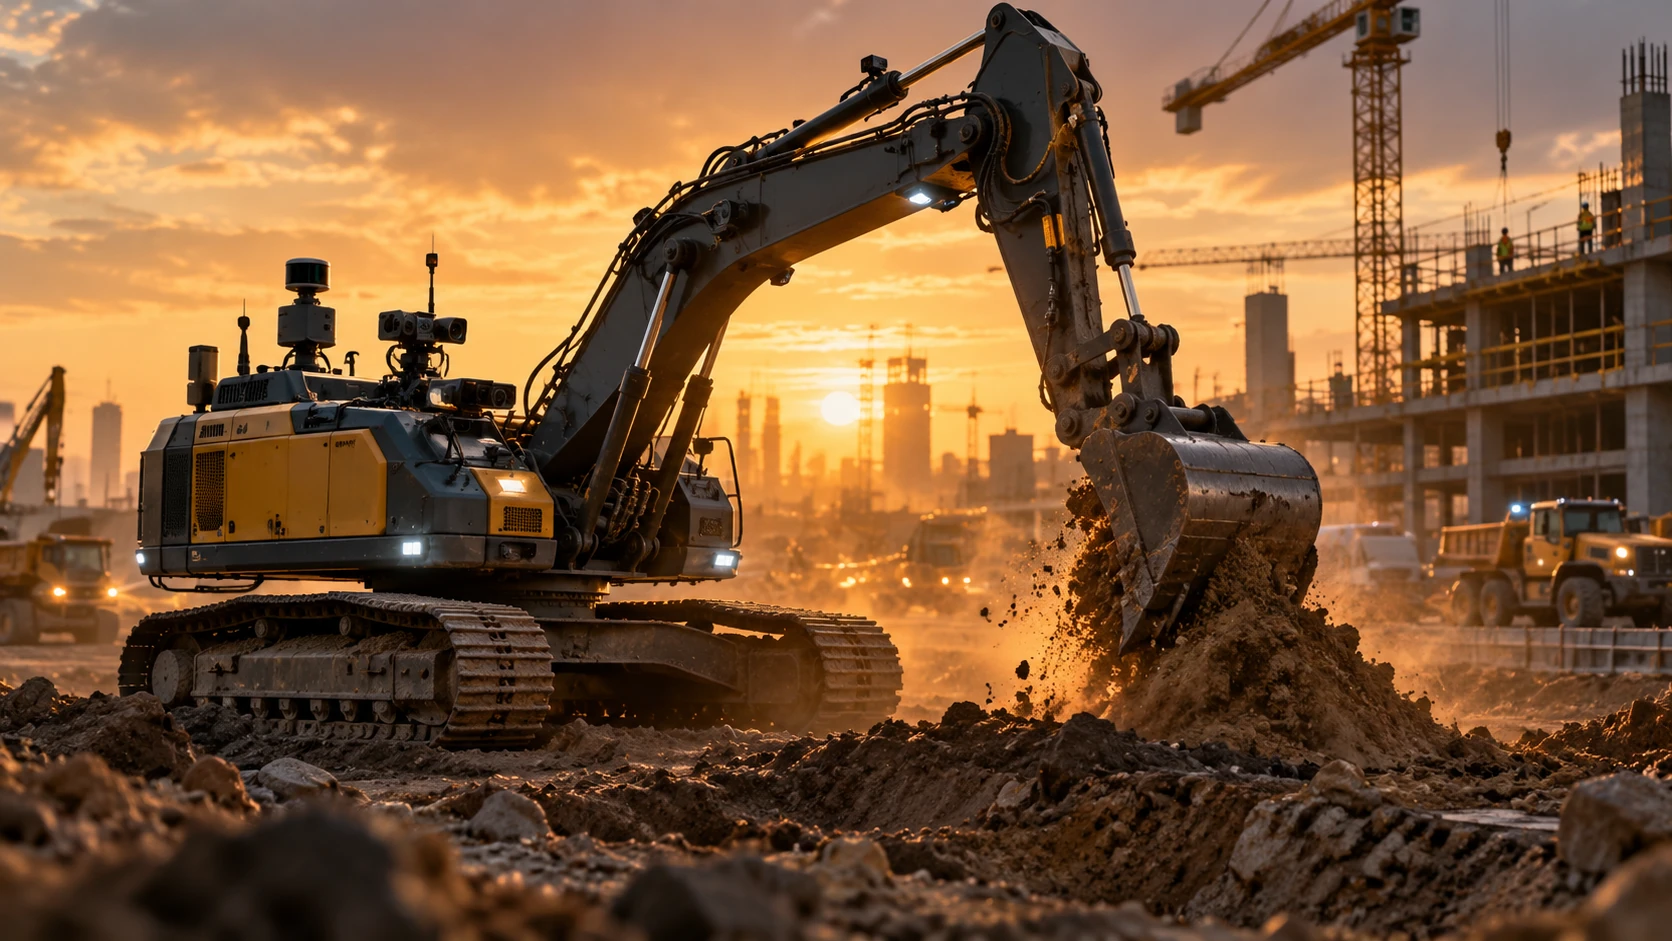
Construction & Infrastructure
Autonomous heavy equipment and site intelligence for dynamic jobsites.
Solutions / 02
Tessoryn is being designed for environments where variability, scale and physical complexity make traditional automation difficult.
01Autonomous heavy equipment and site intelligence for dynamic jobsites.
 02
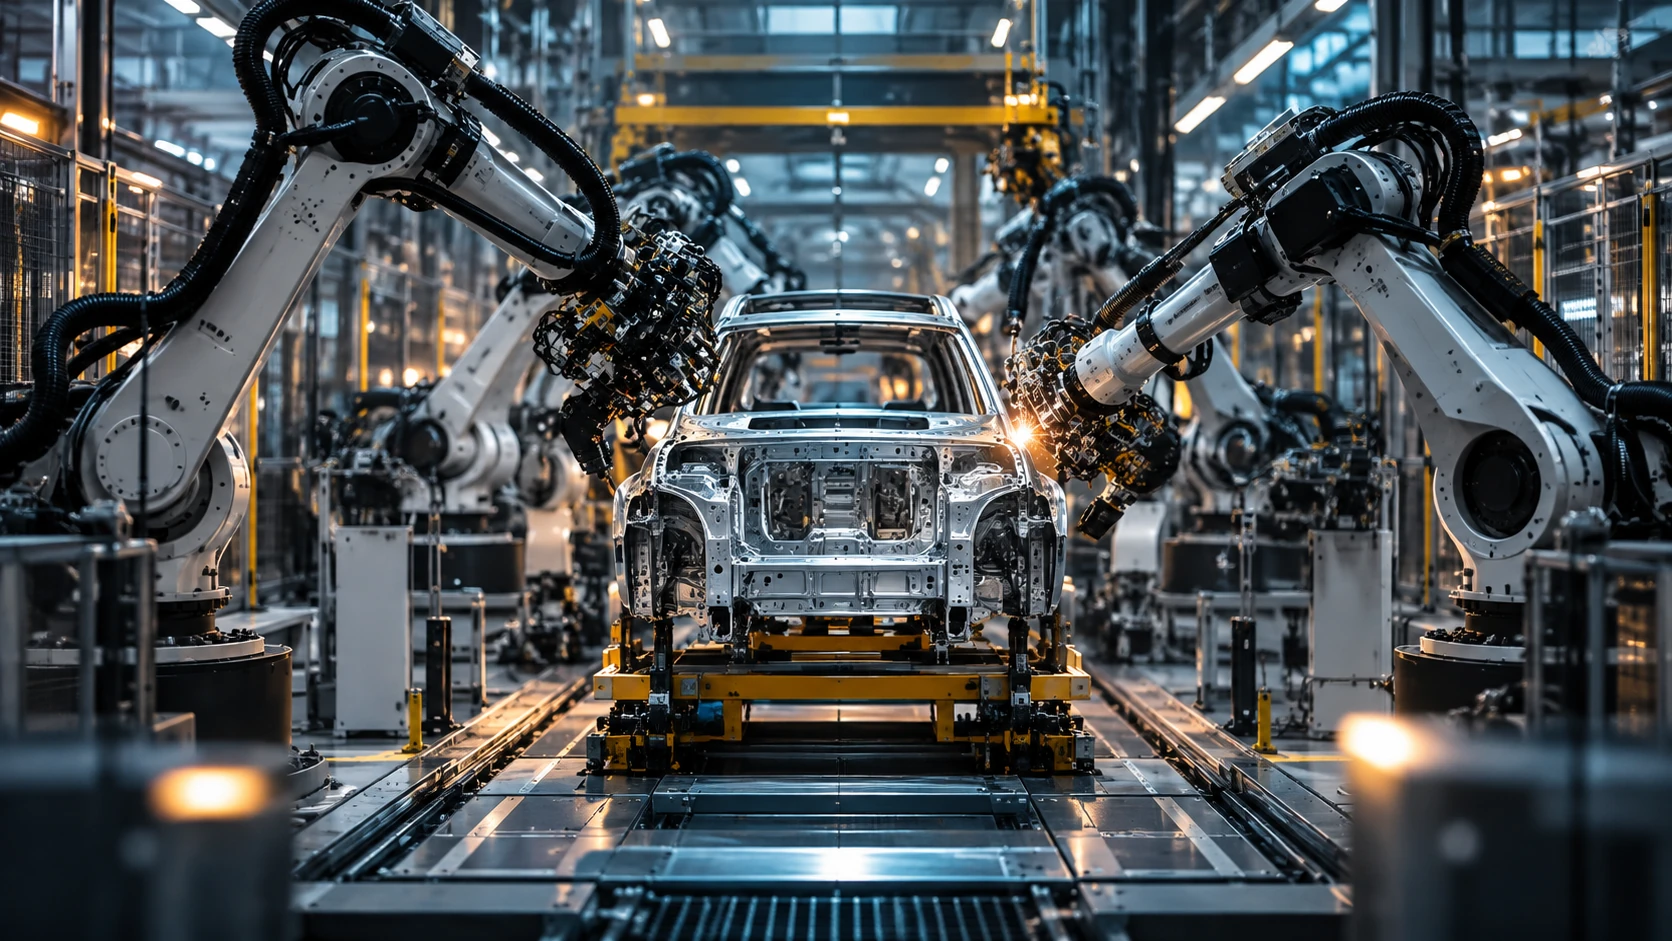
Adaptive robotic systems for changing processes, materials and factory workflows.
 03
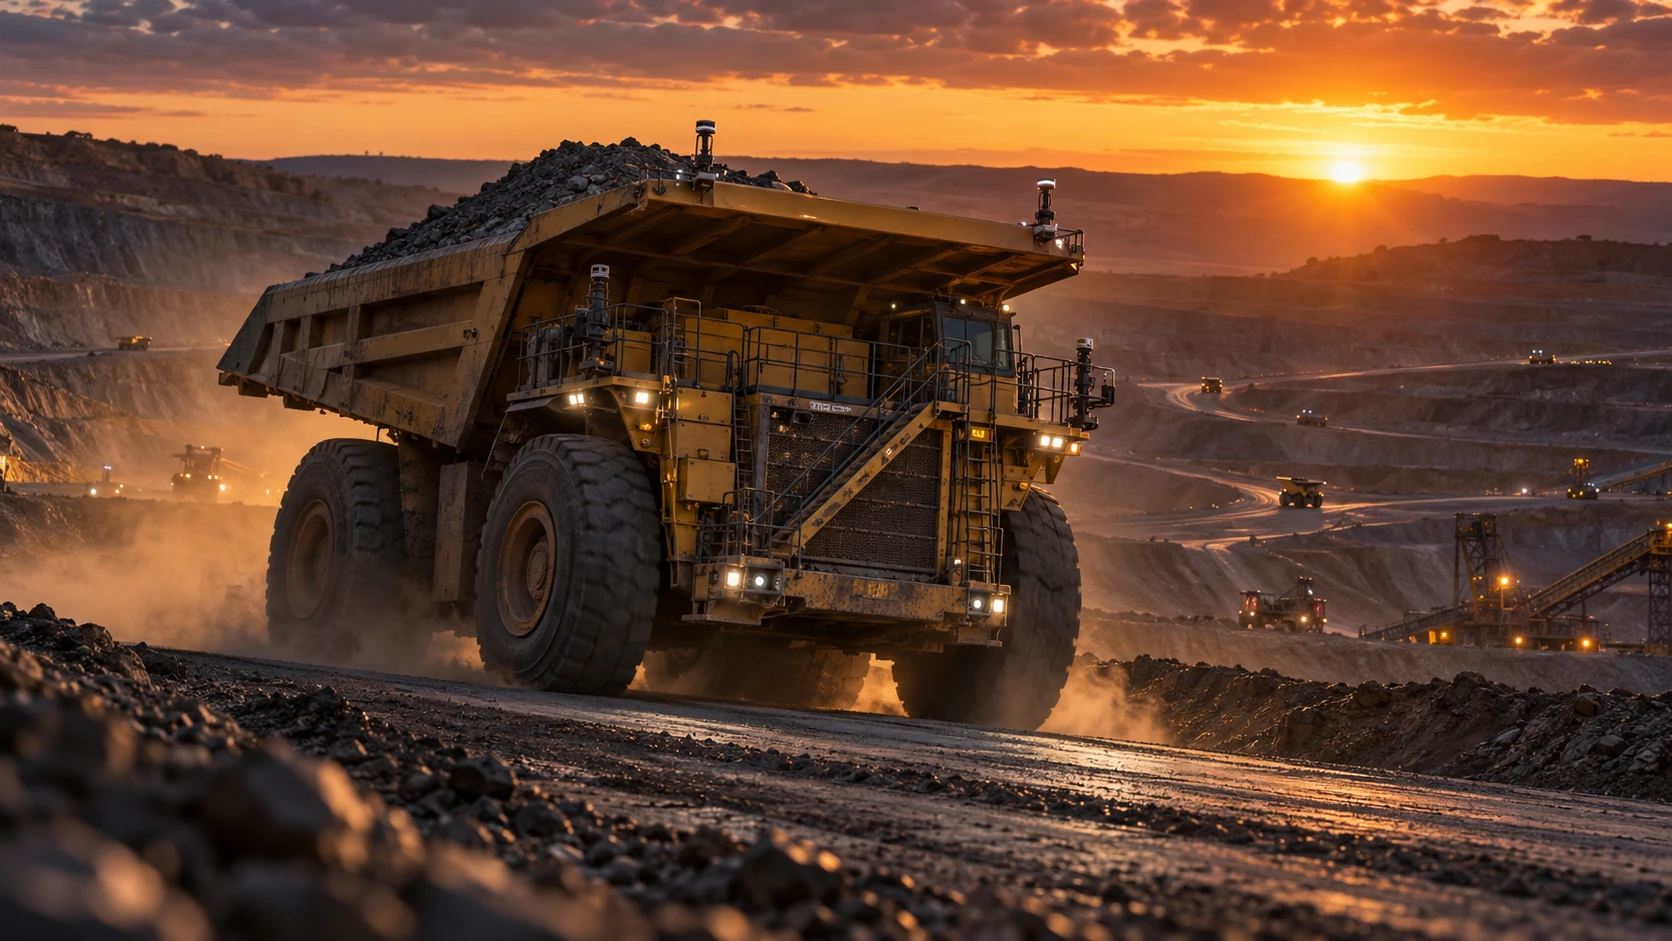
Autonomous machines for large-scale, remote and hazardous environments.
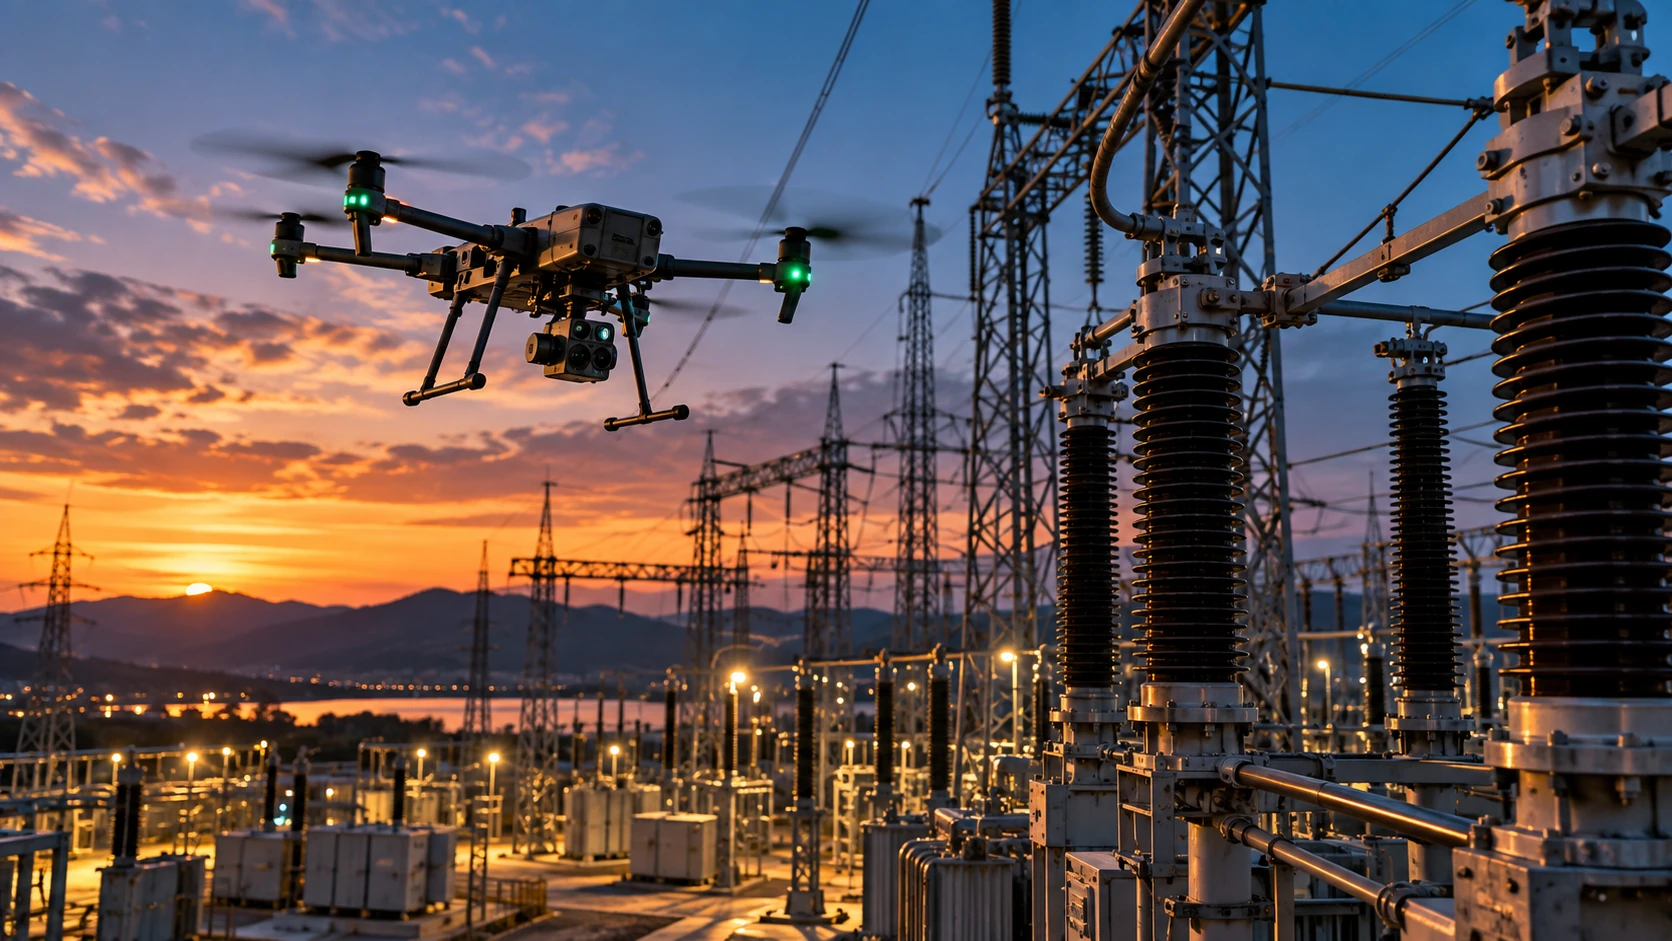 04
Aerial and robotic inspection across critical energy infrastructure.
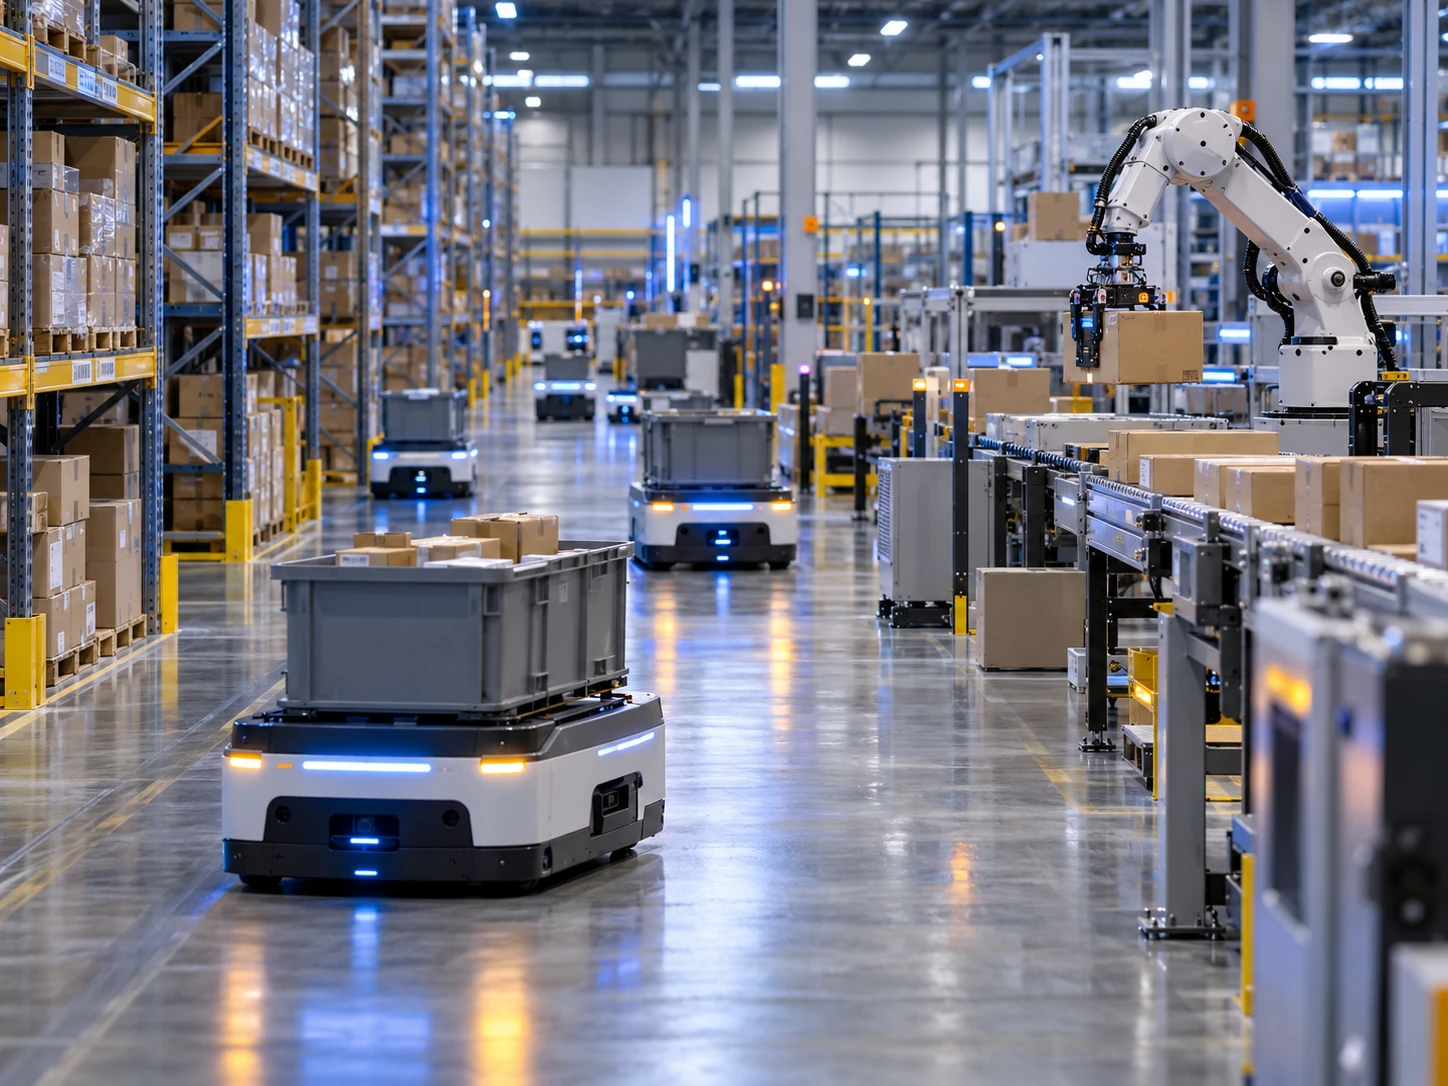 05
Autonomous movement, handling and warehouse operations.
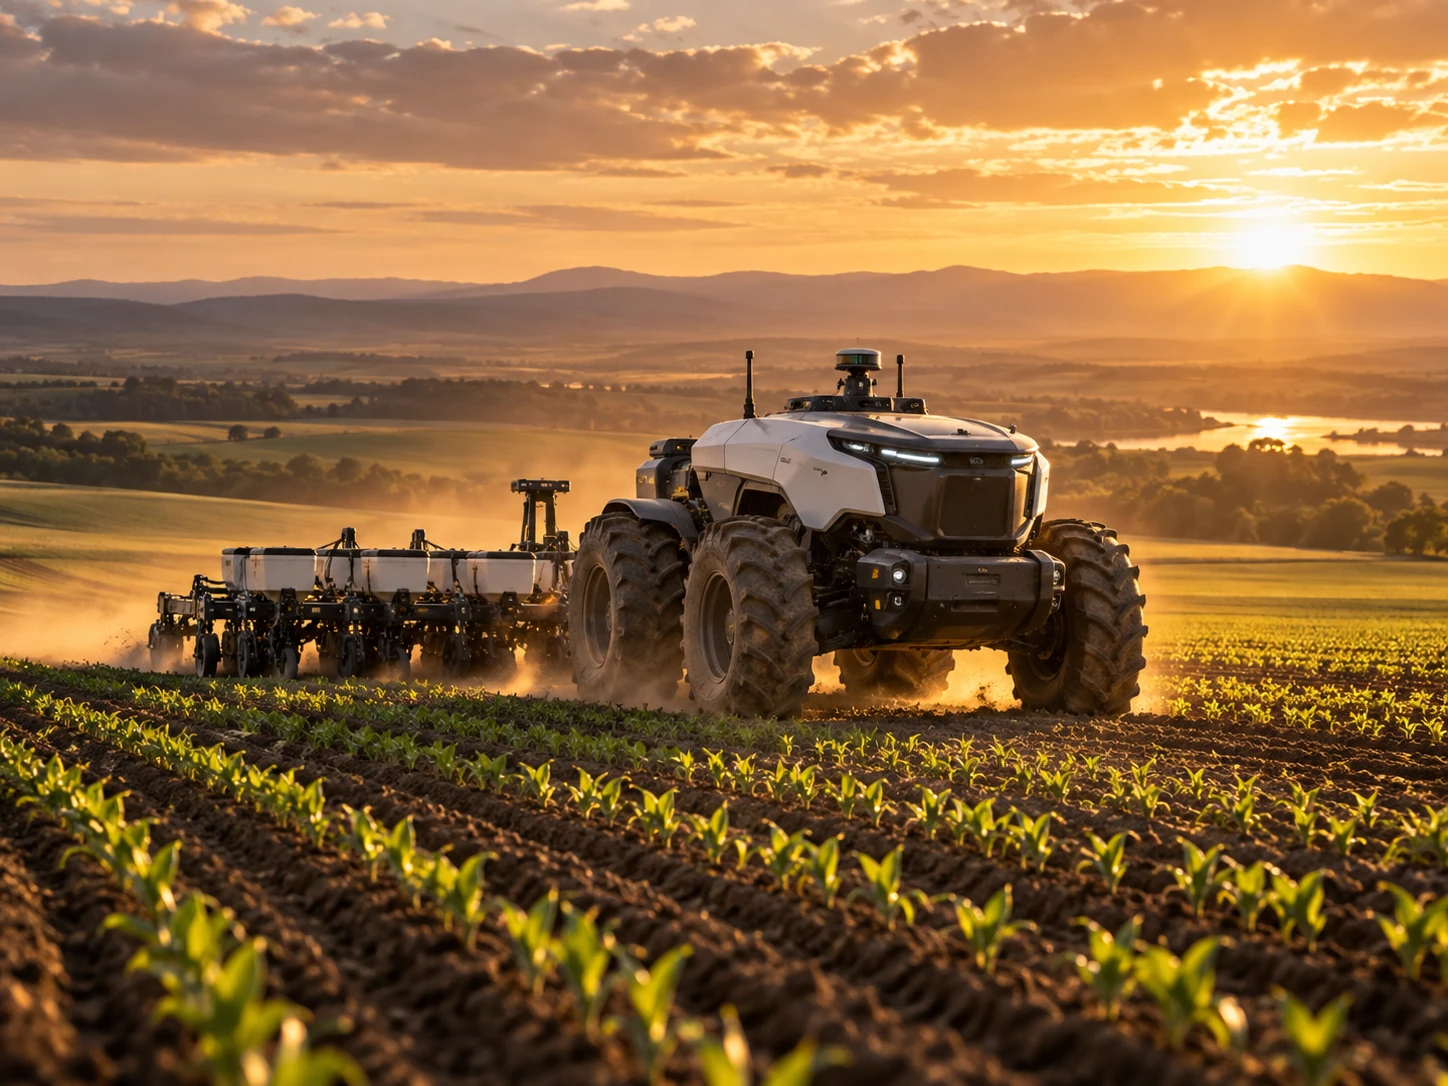 06
Autonomous field operations across changing outdoor environments.
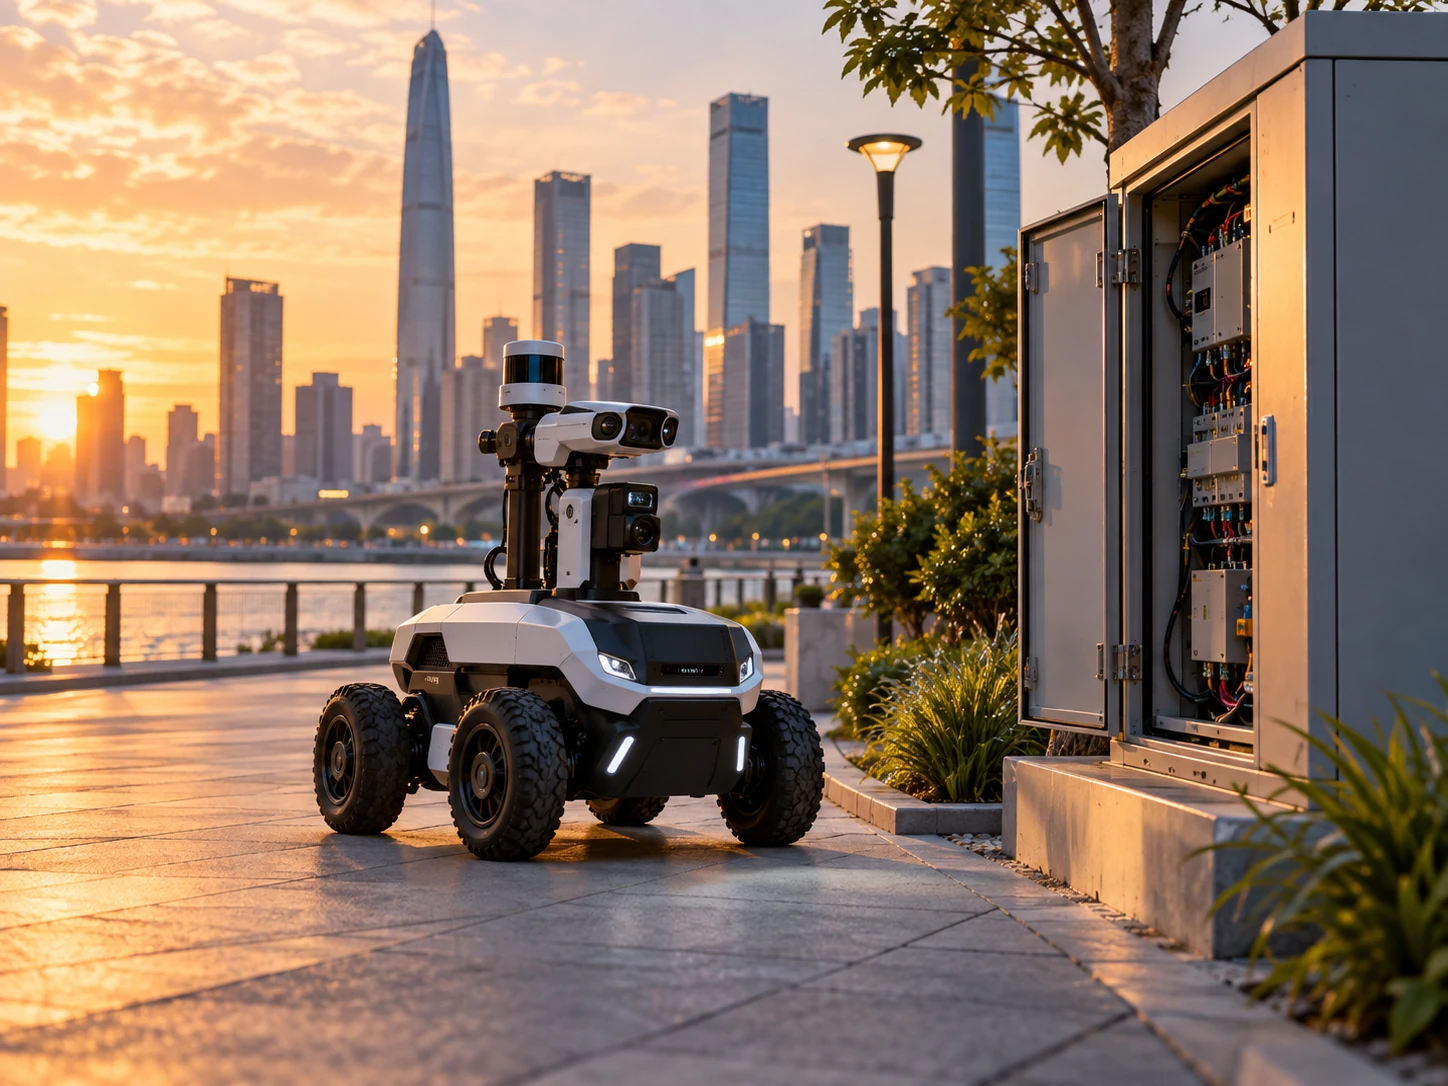 07
Inspection and autonomous operation across complex built environments.
 08
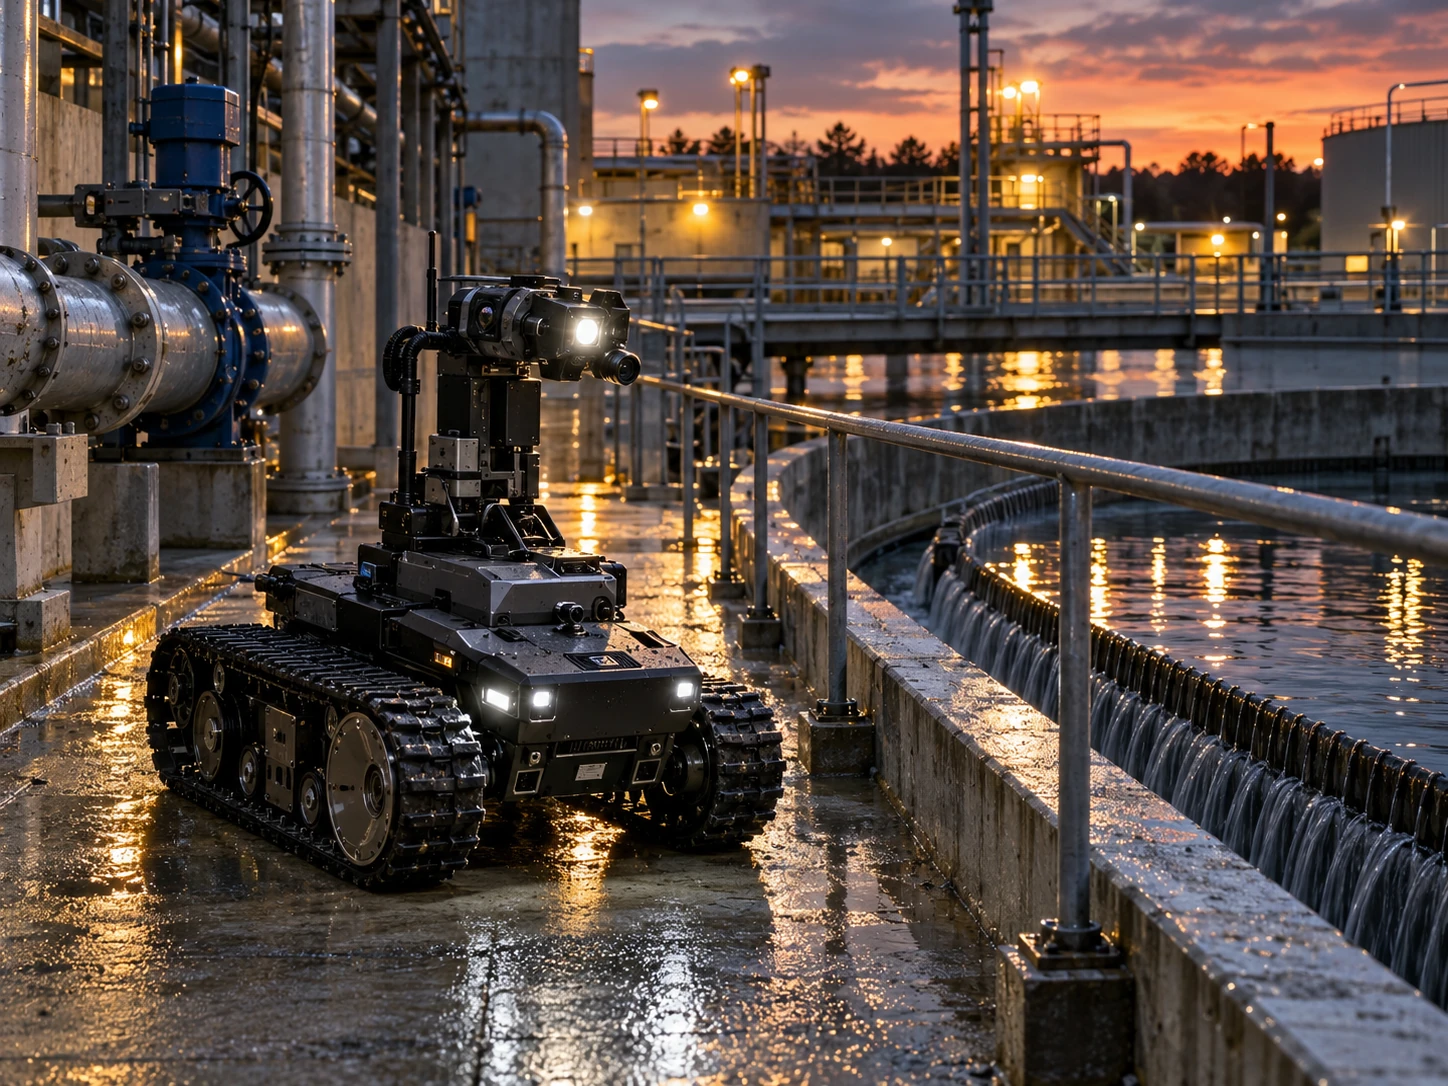
Robotic inspection for difficult, remote and operationally sensitive environments.
Imagery illustrates target operating environments and is not presented as customer deployment footage.
Common challenge
Physical scenes rarely remain identical from one task, shift or location to the next.
Machines must reason about geometry, objects, safety boundaries and changing operating conditions.
Useful autonomy requires decisions to remain connected to what the machine is actually sensing.
Your application
Share the machine, environment and task. We will use that context to understand whether Tessoryn is relevant.